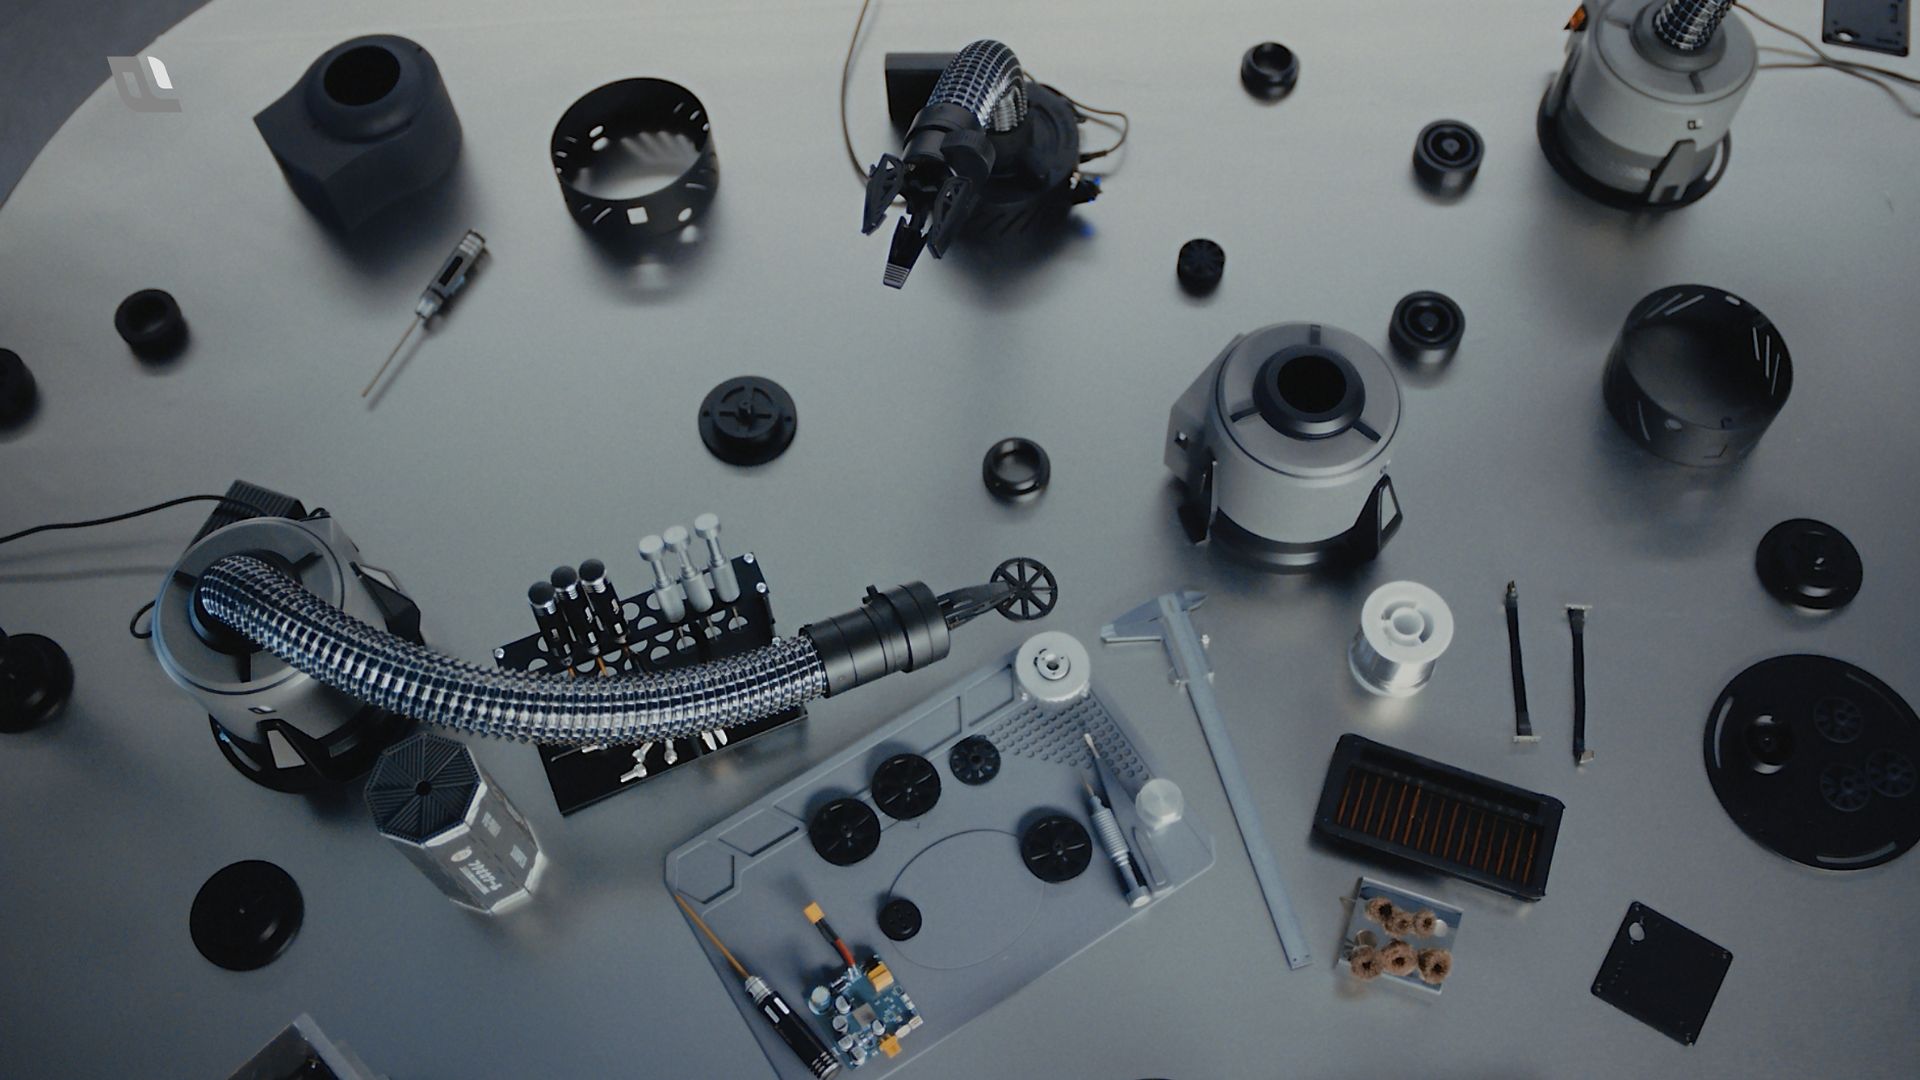
The world of robotics is evolving, and a fascinating development is taking place in China with Feagine Robotics' innovative approach. Imagine a future where robots can learn and adapt across different bodies, much like a versatile 'Doctor Octopus' character. This is precisely what Feagine is aiming for with its cross-embodiment foundation model, Fi0.
The Challenge of Robot Intelligence
In the realm of robotics, a significant challenge arises when a robot's physical structure changes. The intelligence controlling it often needs a complete overhaul, which is an inefficient and time-consuming process. Feagine's solution? Create an AI that can retain task knowledge regardless of the robot's physical form.
Introducing Feagine's Soft Manipulators
To test this concept, Feagine has developed three unique tendon-driven soft manipulators: A01, A02, and A03. Each manipulator offers different lengths, segment counts, and degrees of freedom, providing a systematic approach to understanding the impact of physical differences on robot capabilities.
The Power of Cross-Embodiment Intelligence
The key to Feagine's approach lies in treating the robot's physical structure and current state as integral parts of the information used to generate actions. This cross-embodiment intelligence allows the task to remain consistent, even when the physical method of execution changes. It's like teaching a robot to dance, and it doesn't matter if it has two legs or four; the steps remain the same.
Reducing Retraining Needs
Feagine's Fi0 aims to minimize the need for extensive retraining when robots encounter new tasks. With Fi0, a single human demonstration can provide the context needed for the robot to understand and execute a task, without the need for a lengthy training cycle. This is a significant step towards making robots more adaptable and efficient.
The Rise of Soft Robots
Feagine's deliberate choice to use soft, tendon-driven manipulators adds an interesting layer to this development. Unlike traditional robotic arms, soft robots can bend continuously, change shape, and interact compliantly with their surroundings. This complexity challenges the AI to understand the robot's physical configuration as part of the problem, which is a fascinating and necessary step in the evolution of robotics.
The Future of Robotics: Specialized Machines, Shared Intelligence
The concept of soft embodied intelligence proposed by Feagine suggests that the future of robotics may not revolve around a single universal machine. Different environments will likely require very different robot bodies, each specialized for its task. The intelligence layer, however, could be shared across these machines, reducing the need for each robot to carry the burden of generality.
Beyond Humanoid Robots
While humanoid robots have captured our imagination, Feagine's approach challenges the notion that general-purpose intelligence requires a humanoid body. Instead, they ask: Can one intelligence operate many specialized bodies? This reverse perspective opens up exciting possibilities for the future of robotics, where a diverse range of machines could share a common intelligence layer.
Feagine's work is a significant step towards overcoming a bottleneck in embodied AI, ensuring that the intelligence gained through one robot doesn't become obsolete when the hardware changes. With further development and real-world testing, this concept could shape the future of robotics, leading to a diverse family of specialized machines, all powered by an increasingly capable intelligence layer.